Crash reconstruction · Demo
A 36-second intersection reconstruction. The motion is calculated from case data and built in Blender. The photoreal look is rendered on top of it, frame for frame.
The case
Six inputs define the whole event. Everything you see on screen follows from them.
Fictional case created for a portfolio. Values are typical for an urban arterial intersection.
01 · Physics
Before any design, a small Python model steps both vehicles through time: speed, braking, the truck's turning radius and the trailer following its kingpin. Every position in the film comes from this table, 30 times per second.
02 · Scene
The intersection, the tractor, the 53-foot trailer and the sedan are modeled at real dimensions and driven by the simulation data. Cameras are animated per shot. The crash itself is modeled too: the hood buckles, the windshield cracks, debris falls.
The Blender scene, played back with its own cameras: drone flyover, impact close-up, after-crash orbit.
03 · Motion trackers
Each shot is rendered as a clean greyscale pass with no color and no text. It carries only shape and motion, so the next step can change the look without ever changing where the vehicles are.
Drone overview
Driver's view
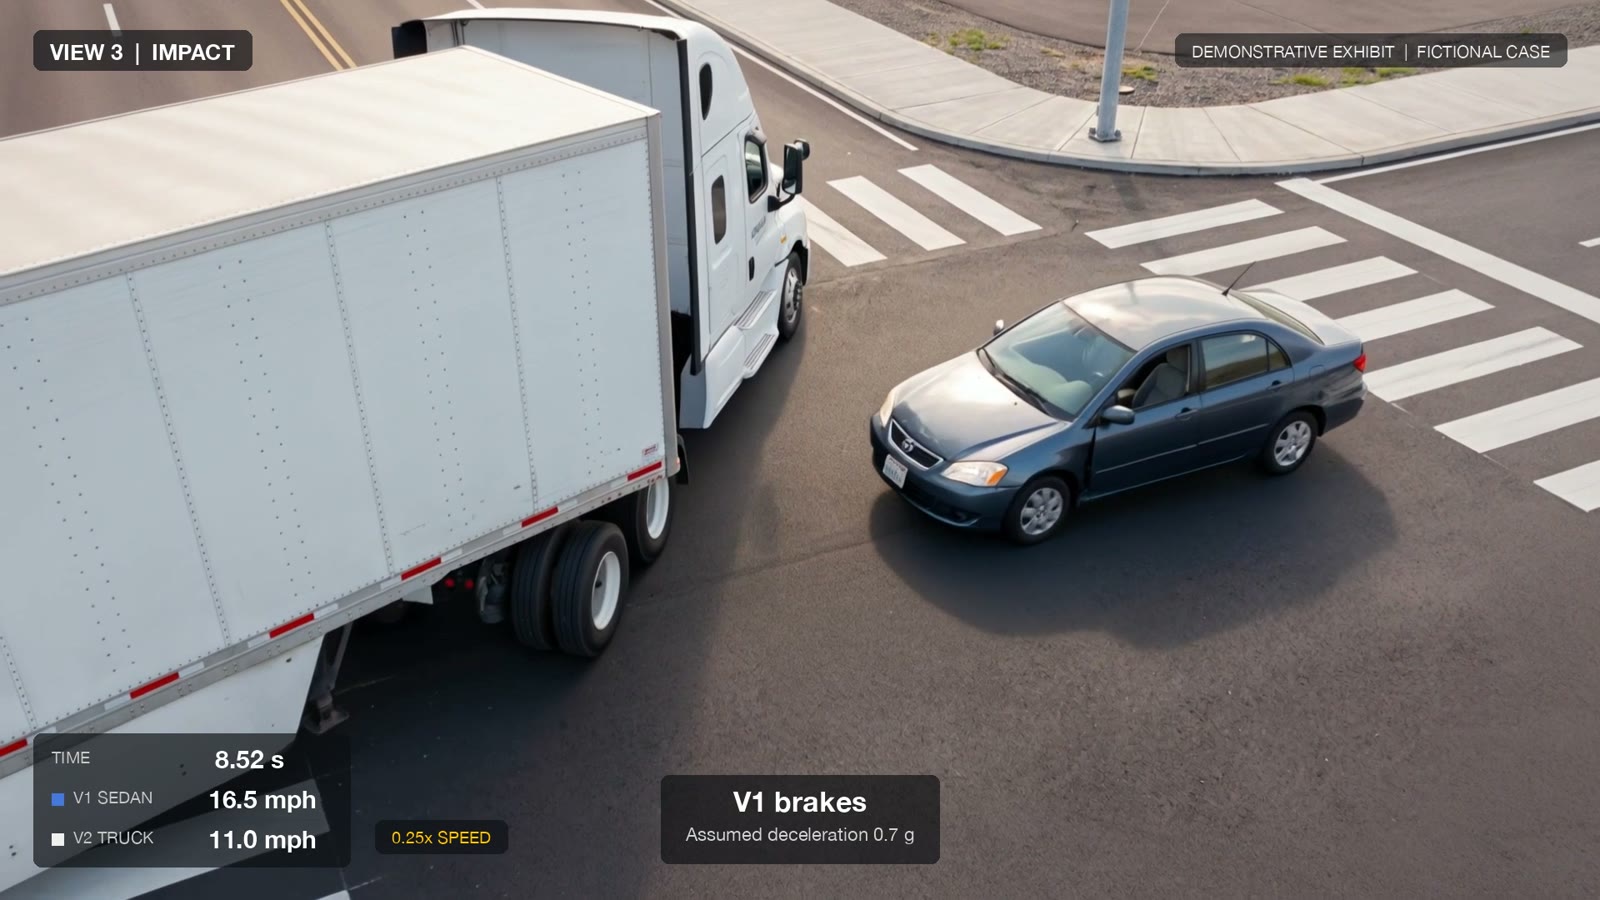
Impact, 0.25× speed
Final rest, orbit
Alternate: truck yields
04 · Look development
One master frame sets the visual standard: soft late-morning light, fresh asphalt, a believable Texas suburb. Then every shot gets its own first frame, checked against the grey pass so nothing drifts.
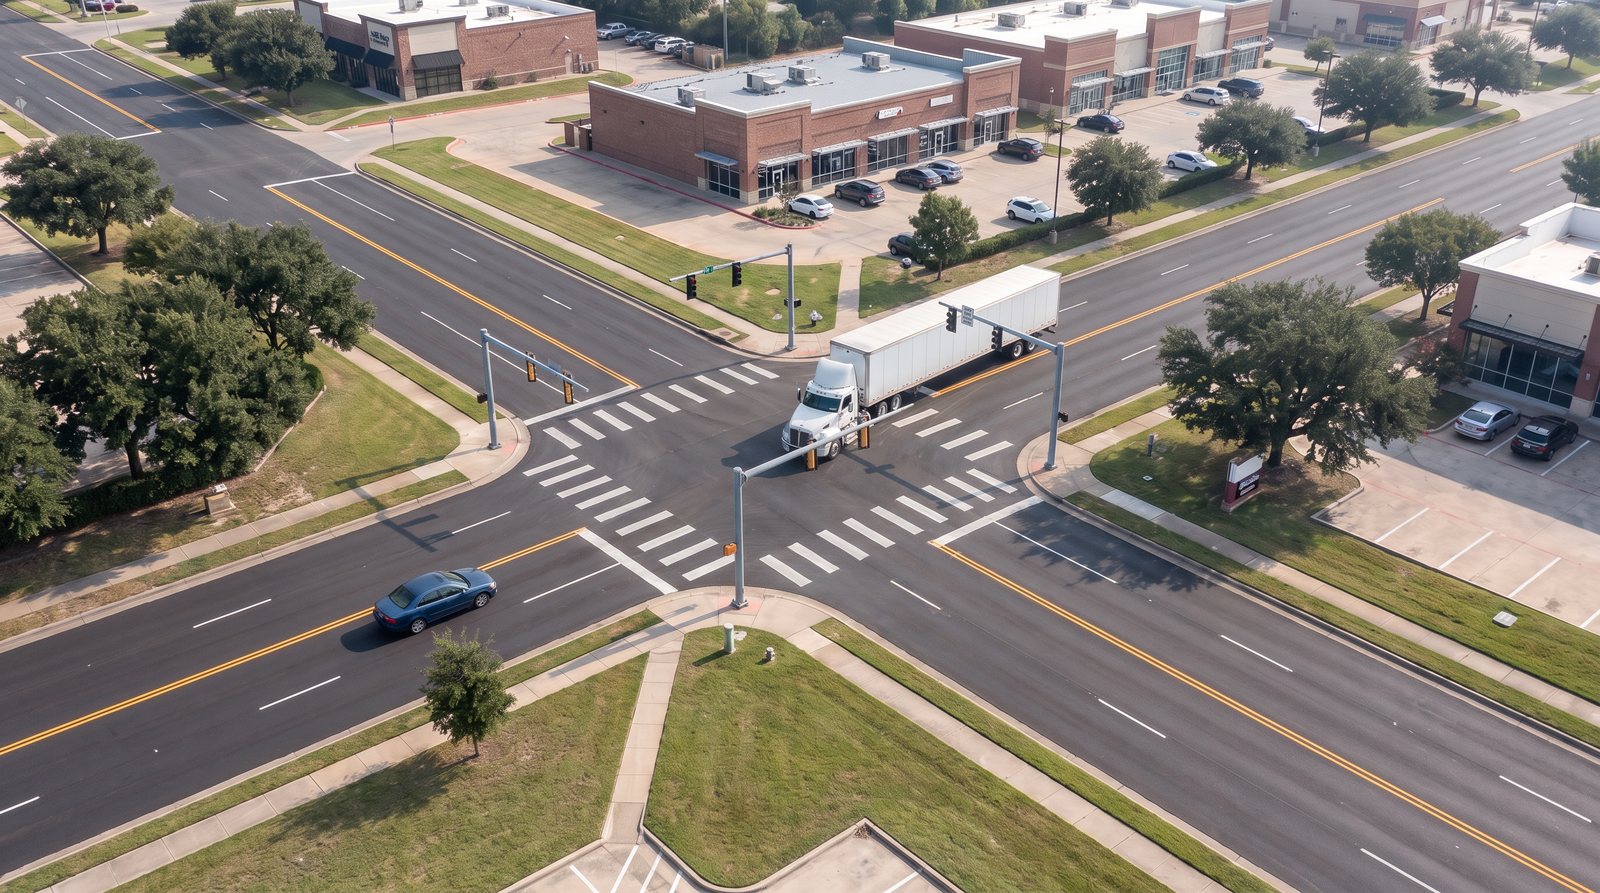
Master look frame.
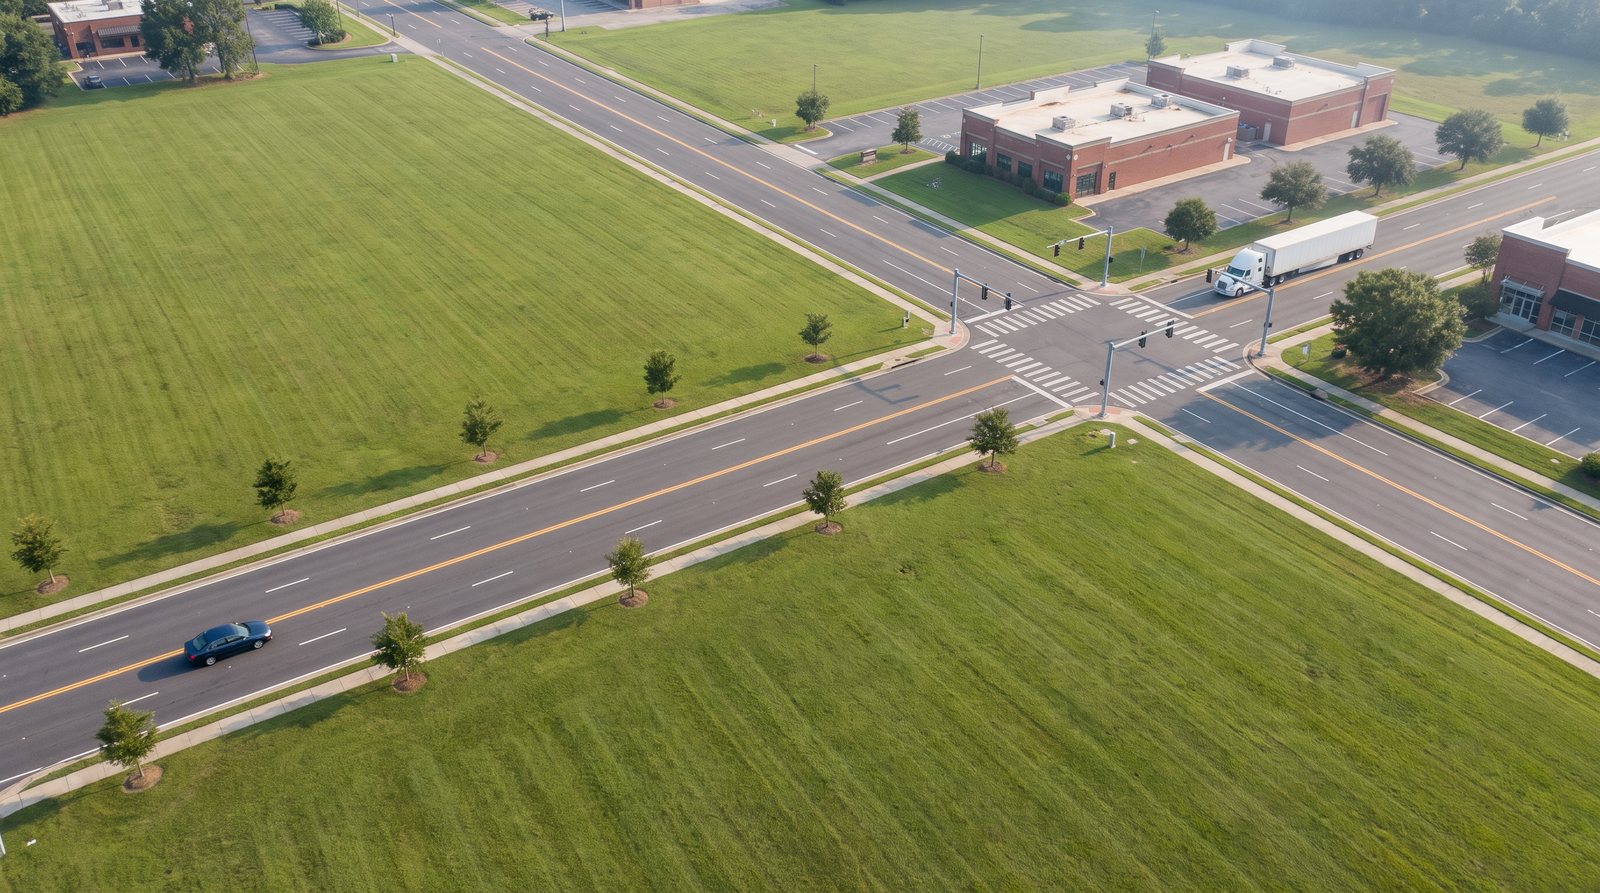
Drone overview
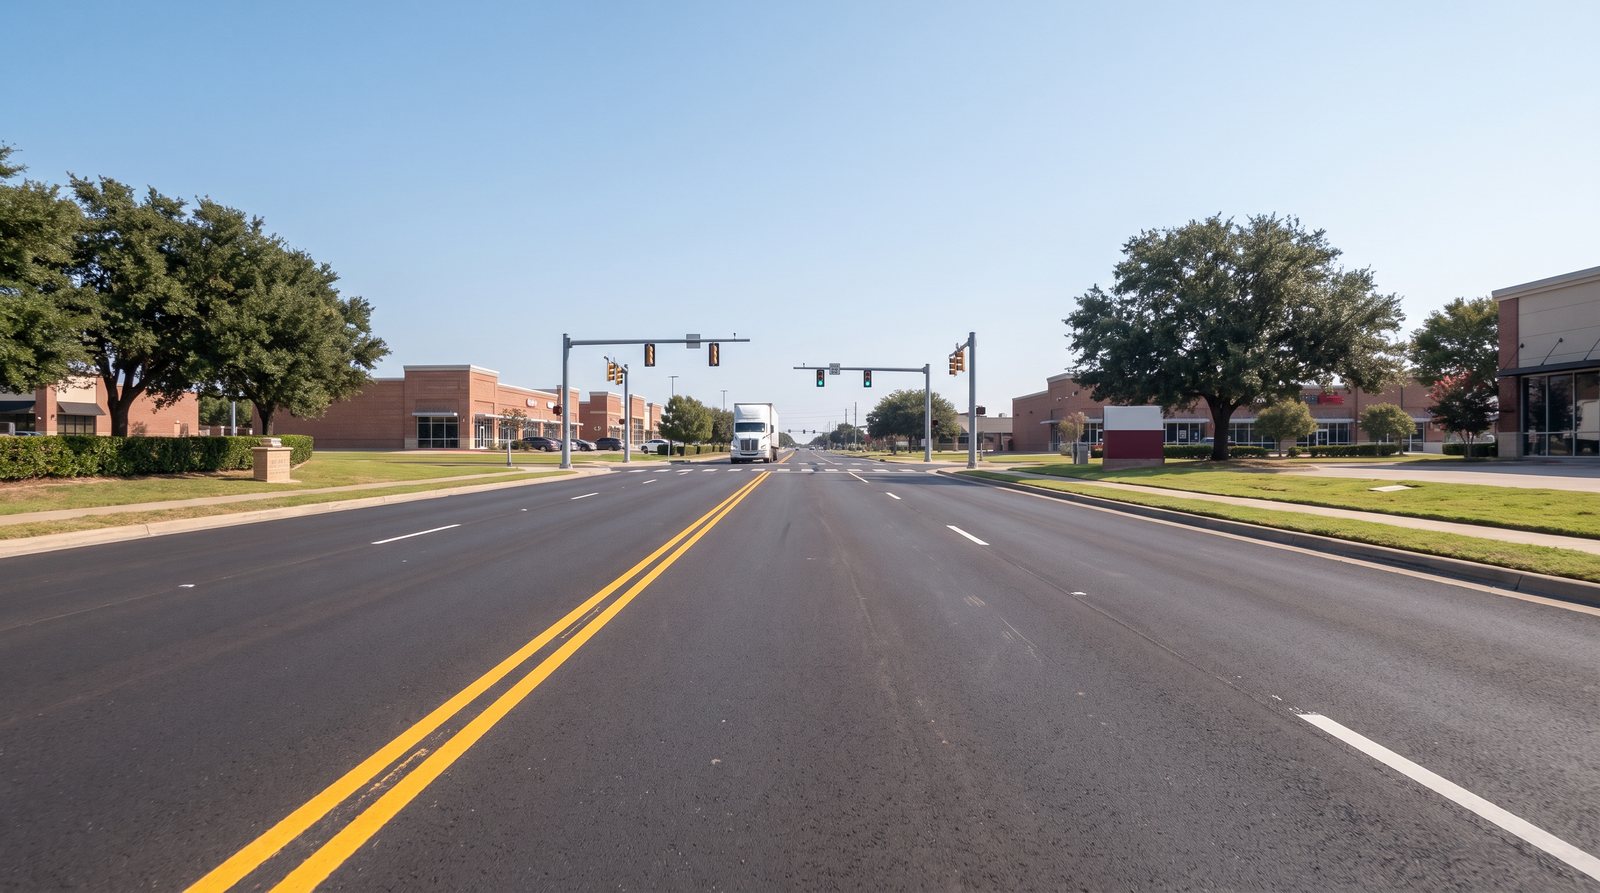
Driver's view
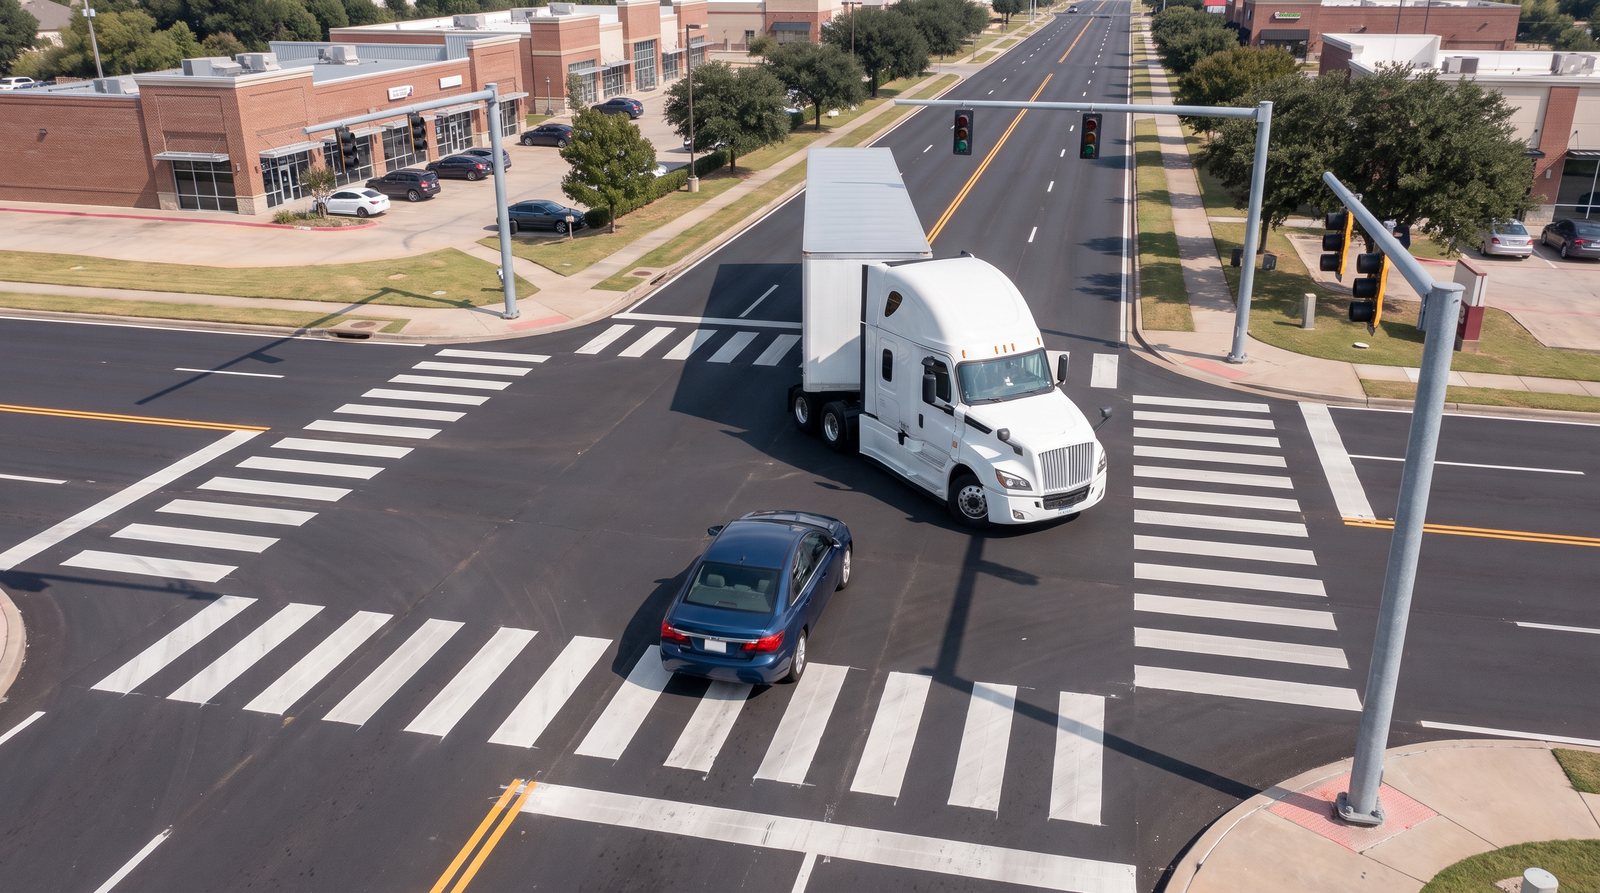
Impact
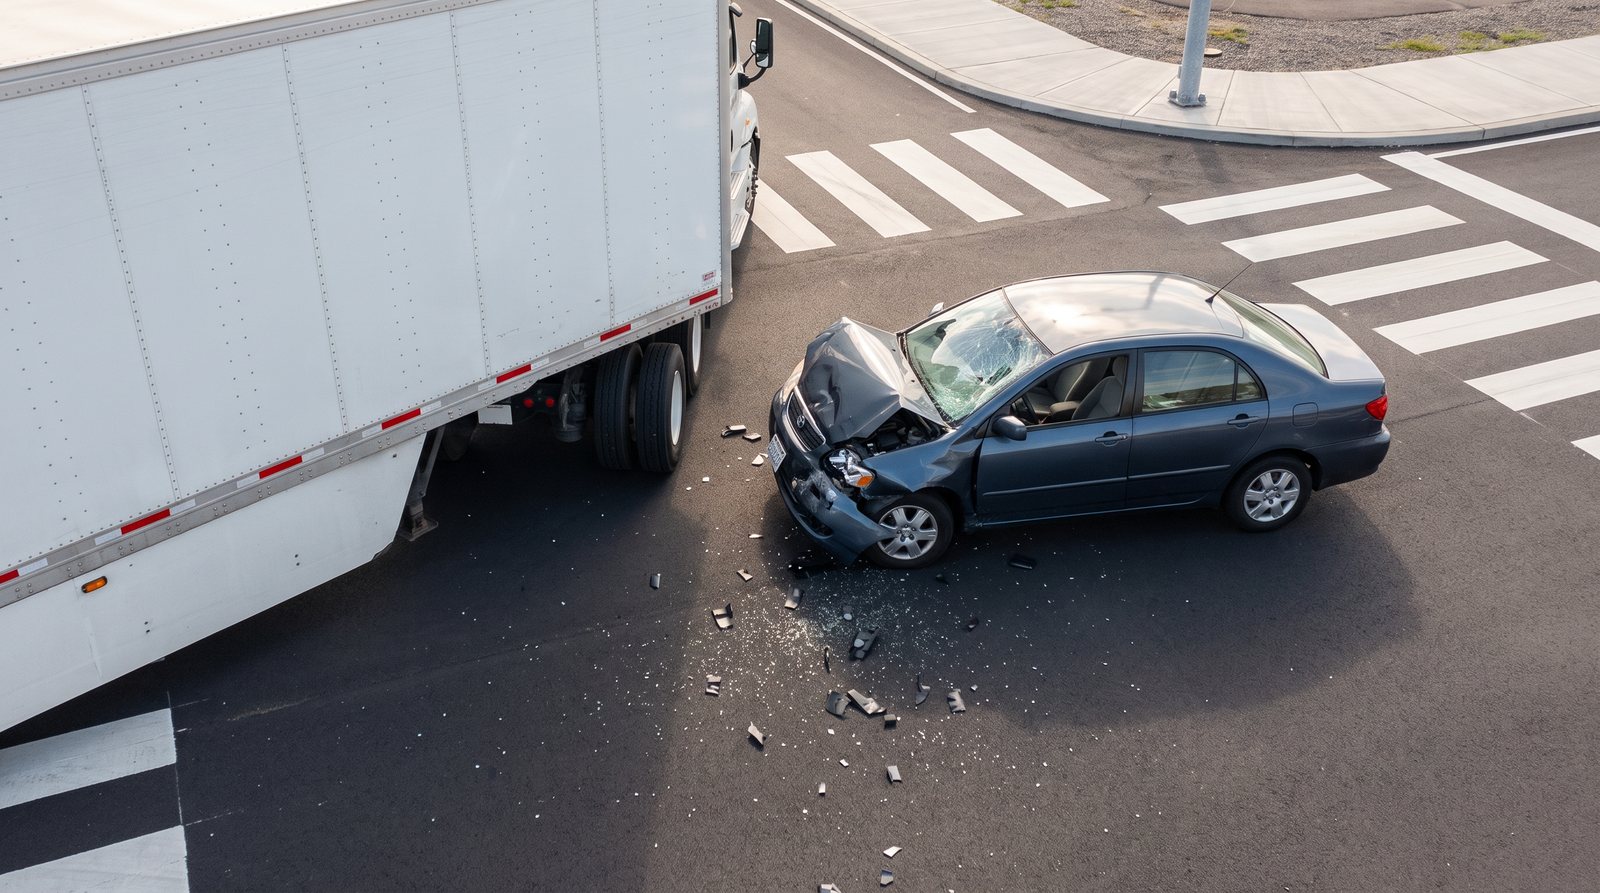
Damage reference
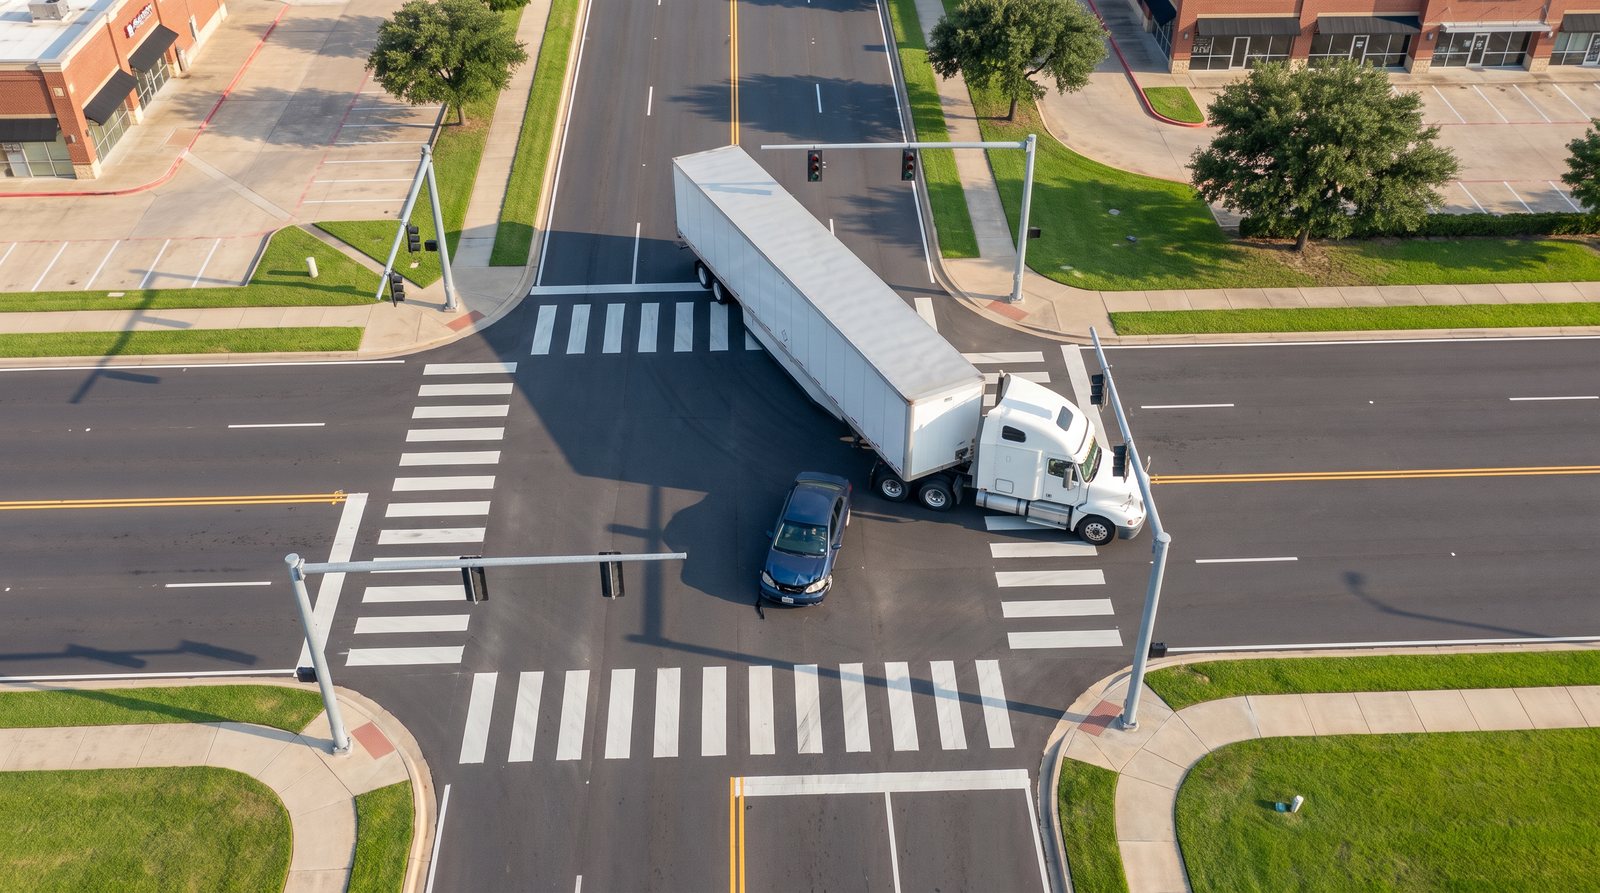
Final rest
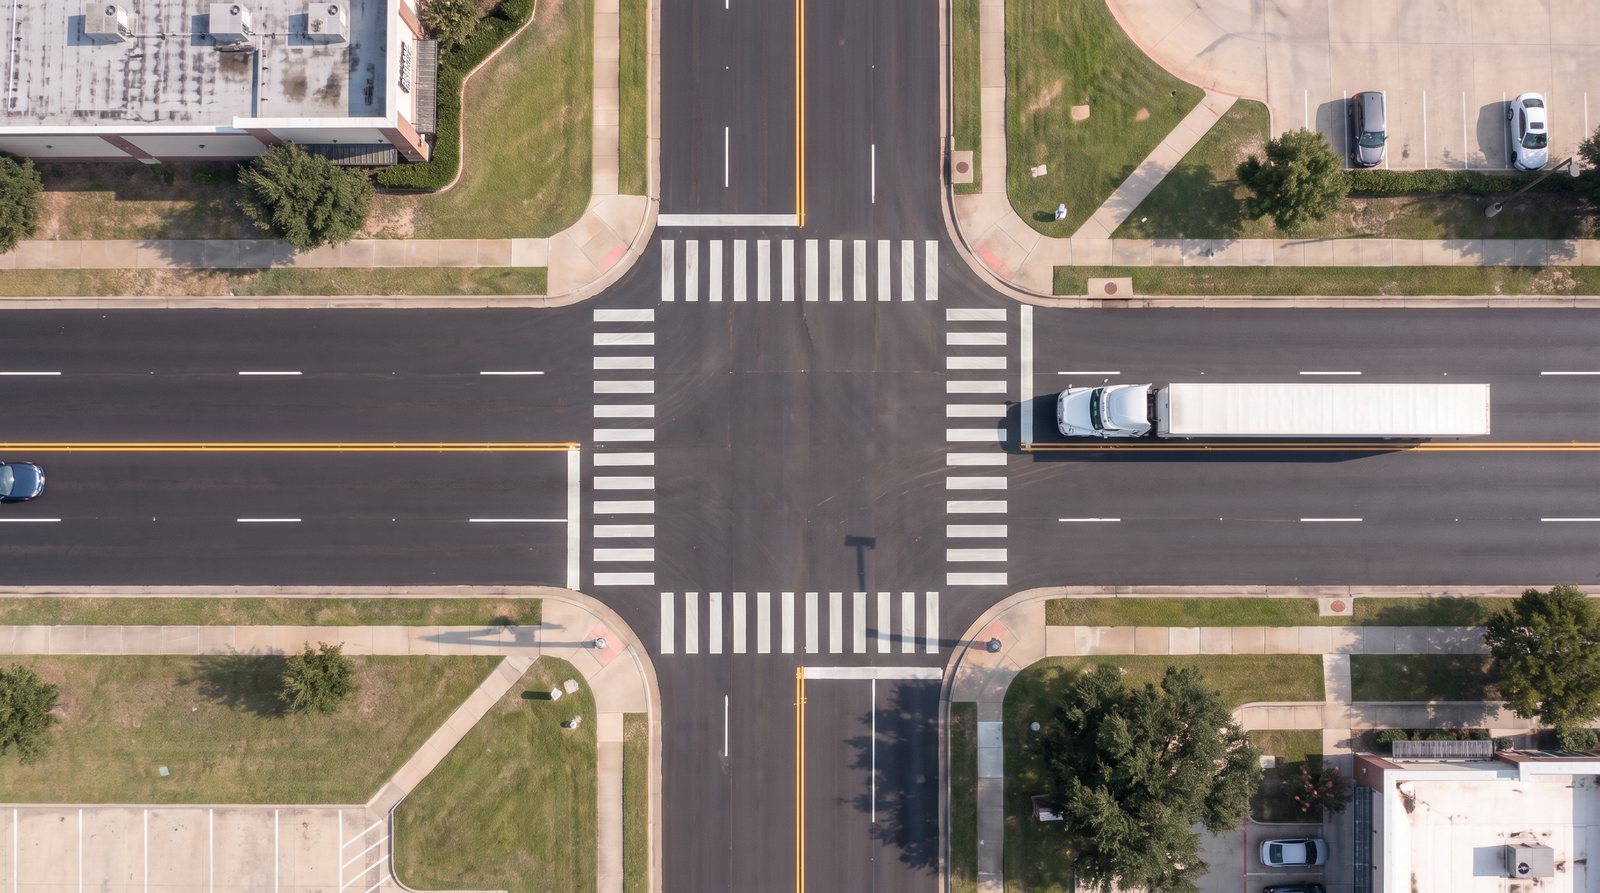
Alternate scenario
05 · Render
The grey pass drives the motion. The approved frames drive the look. The result keeps the calculated paths, timing and point of impact, and adds the realism.
Drone overview
Driver's view
Final rest, orbit
Alternate: truck yields

06 · Edit
Time, speeds and event captions are generated straight from the simulation, frame by frame. When the sedan brakes, the number drops on screen exactly as the model says.
The pipeline
Python model of both vehicles, 30 samples per second.
Blender scene to scale, cameras and crash deformation.
Grey motion passes plus approved look frames, rendered photoreal with Kling.
Edit and on-screen data generated from the same simulation.
Accurate first. Beautiful always. I would love to do this for your cases.
See more work on BehanceSerge Tretiakov · 3D & Motion Designer · behance.net/tretiakov-design